This session covers the optimal binary search tree problem. A normal binary search tree only depends on key order, but an optimal BST also considers how frequently each key is searched so that the expected search cost is minimized.
Objectives
Do not copy. Read for understanding and the viva- Understand optimal binary search tree construction.
- Determine the minimum expected search cost.
- Show the final tree structure for the given key probabilities/frequencies.
Concept
Do not copy. Read for understanding and the vivaAn optimal binary search tree minimizes the expected search cost when keys have different search probabilities. Frequently searched keys should appear closer to the root when that reduces total weighted path cost.
Dynamic Programming Idea
Do not copy. Read for understanding and the vivaFor each key range, try each key as root and choose the root that gives minimum expected cost.
cost[i][j] = min(cost[i][r-1] + cost[r+1][j] + sum(freq[i..j]))where r ranges from i to j.
Question 1
Problem Statement
Write in lab recordDetermine the cost and structure of an optimal binary search tree for a set of n = 7 keys with the given properties. Show the step-by-step process.
| i | 0 | 1 | 2 | 3 | 4 | 5 | 6 | 7 |
|---|---|---|---|---|---|---|---|---|
| 0.04 | 0.06 | 0.08 | 0.02 | 0.10 | 0.12 | 0.14 | ||
| 0.06 | 0.06 | 0.06 | 0.06 | 0.05 | 0.05 | 0.05 | 0.05 |
Explanation
Do not copy. Read for understanding and the vivaOptimal Tree Structure
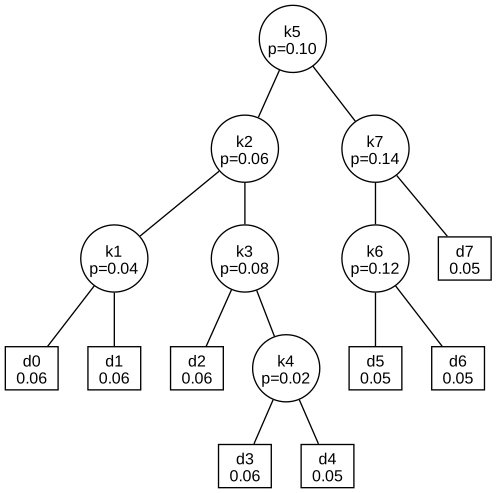
Write in lab recordFor n = 7 keys with the given probabilities, the minimum expected search cost is 3.12 (exactly 78/25) with at the root.
Step-by-Step
Write in lab recordThe OBST problem is solved using the standard CLRS dynamic programming approach. We maintain three tables:
e[i][j]: Expected search cost for keys tow[i][j]: Sum of probabilities in the subtree (keys + dummy keys)root[i][j]: Index of the root key that minimizese[i][j]
Recurrence Relations
Do not copy. Read for understanding and the viva- Base Case: for i = 1 to n+1
- Weight Update:
- Cost Update:
Table Initialization
Do not copy. Read for understanding and the vivae[1][0] = 0.06, e[2][1] = 0.06, e[3][2] = 0.06, e[4][3] = 0.06
e[5][4] = 0.05, e[6][5] = 0.05, e[7][6] = 0.05, e[8][7] = 0.05
w[i][i-1] = e[i][i-1]Filling Tables (Length l = 1 to 7)
We iterate over subtree lengths l, then start index i, compute j = i + l - 1, calculate w[i][j], and try every possible root r between i and j.
Example for l=1, i=1, j=1:
w[1][1] = w[1][0] + p_1 + q_1 = 0.06 + 0.04 + 0.06 = 0.16e[1][1] = e[1][0] + e[2][1] + w[1][1] = 0.06 + 0.06 + 0.16 = 0.28root[1][1] = 1
Repeating this for all l yields the final tables:
e[i][j] | 1 | 2 | 3 | 4 | 5 | 6 | 7 |
|---|---|---|---|---|---|---|---|
| 1 | 0.28 | 0.62 | 1.02 | 1.34 | 1.83 | 2.44 | 3.12 |
| 2 | 0.30 | 0.68 | 0.93 | 1.41 | 1.96 | 2.61 | |
| 3 | 0.32 | 0.57 | 1.04 | 1.48 | 2.13 | ||
| 4 | 0.24 | 0.57 | 1.01 | 1.55 | |||
| 5 | 0.30 | 0.72 | 1.20 | ||||
| 6 | 0.32 | 0.78 | |||||
| 7 | 0.34 |
root[i][j] | 1 | 2 | 3 | 4 | 5 | 6 | 7 |
|---|---|---|---|---|---|---|---|
| 1 | 1 | 2 | 2 | 2 | 3 | 3 | 5 |
| 2 | 2 | 3 | 3 | 3 | 5 | 5 | |
| 3 | 3 | 3 | 4 | 5 | 5 | ||
| 4 | 4 | 5 | 5 | 6 | |||
| 5 | 5 | 6 | 6 | ||||
| 6 | 6 | 7 | |||||
| 7 | 7 |
Check on the diagonal: e[4][4] = e[4][3] + e[5][4] + w[4][4] = 0.06 + 0.05 + (0.06 + 0.02 + 0.05) = 0.24. Note , not 0.06; that is where a hand calculation usually slips.
Tree Reconstruction
Starting from root[1][7] = 5, we recursively find subtrees:
root[1][4] = 2→ is the left child of ;root[6][7] = 7→ is the right child.root[1][1] = 1androot[3][4] = 3→ and under ;root[4][4] = 4→ is the right child of .root[6][6] = 6→ is the left child of ; the right child of is the dummy .- Every empty range
[i, i-1]becomes the dummy leaf : under ; under ; under ; under .
Implementation
Write in lab recordLab record: write one language only. Pick yours once and every page opens on it; the other tabs are the same solution for comparison.
def optimal_bst(p, q):
    n = len(p) - 1  # p is 1-indexed, so length is n+1
    # e[i][j] stores expected cost, w[i][j] stores probability sum
    e = [[0.0] * (n + 2) for _ in range(n + 2)]
    w = [[0.0] * (n + 2) for _ in range(n + 2)]
    root = [[0] * (n + 1) for _ in range(n + 1)]

    # Base cases: single dummy keys
    for i in range(1, n + 2):
        e[i][i - 1] = q[i - 1]
        w[i][i - 1] = q[i - 1]

    # DP over chain length l
    for l in range(1, n + 1):
        for i in range(1, n - l + 2):
            j = i + l - 1
            e[i][j] = float("inf")
            w[i][j] = w[i][j - 1] + p[j] + q[j]

            # Try every key as root
            for r in range(i, j + 1):
                t = e[i][r - 1] + e[r + 1][j] + w[i][j]
                if t < e[i][j]:
                    e[i][j] = t
                    root[i][j] = r
    return e, root


def print_tree(root, i, j, depth=0, is_left=True):
    """Recursively print the tree structure"""
    prefix = "L" if is_left else "R"
    indent = "    " * depth
    if i > j:
        print(f"{indent}{prefix} -> d{i - 1} (q={q[i - 1]:.2f})")
        return

    r = root[i][j]
    print(f"{indent}{prefix} -> k{r} (p={p[r]:.2f})")
    print_tree(root, i, r - 1, depth + 1, True)
    print_tree(root, r + 1, j, depth + 1, False)


if __name__ == "__main__":
    p = [0, 0.04, 0.06, 0.08, 0.02, 0.10, 0.12, 0.14]
    q = [0.06, 0.06, 0.06, 0.06, 0.05, 0.05, 0.05, 0.05]
    e, root = optimal_bst(p, q)
    print(f"Optimal Expected Cost: {e[1][len(p) - 1]:.4f}\n")
    print("Tree Structure:")
print_tree(root, 1, len(p) - 1)#include <stdio.h>
#include <stdlib.h>
#include <float.h>
#define N 7
void construct_optimal_bst(double p[], double q[], double e[][N+2], int root[][N+1]) {
double w[N+2][N+2];
// Initialize base cases
for (int i = 1; i <= N + 1; i++) {
e[i][i-1] = q[i-1];
w[i][i-1] = q[i-1];
}
// DP over subtree length l
for (int l = 1; l <= N; l++) {
for (int i = 1; i <= N - l + 1; i++) {
int j = i + l - 1;
e[i][j] = DBL_MAX;
w[i][j] = w[i][j-1] + p[j] + q[j];
for (int r = i; r <= j; r++) {
double t = e[i][r-1] + e[r+1][j] + w[i][j];
if (t < e[i][j]) {
e[i][j] = t;
root[i][j] = r;
}
}
}
}
}
void print_tree(int root[][N+1], int i, int j, int depth, char side) {
if (i > j) {
printf("%*c%c -> d%d\n", depth * 4, ' ', side, i-1);
return;
}
int r = root[i][j];
printf("%*c%c -> k%d\n", depth * 4, ' ', side, r);
print_tree(root, i, r-1, depth+1, 'L');
print_tree(root, r+1, j, depth+1, 'R');
}
int main() {
double p[] = {0, 0.04, 0.06, 0.08, 0.02, 0.10, 0.12, 0.14};
double q[] = {0.06, 0.06, 0.06, 0.06, 0.05, 0.05, 0.05, 0.05};
double e[N+2][N+2];
int root[N+1][N+1];
construct_optimal_bst(p, q, e, root);
printf("Optimal Expected Cost: %.4f\n", e[1][N]);
printf("\nTree Structure:\n");
print_tree(root, 1, N, 0, 'R');
return 0;
}fn optimal_bst(p: &[f64], q: &[f64]) -> (Vec<Vec<f64>>, Vec<Vec<usize>>) {
let n = p.len() - 1;
let mut e = vec![vec![0.0; n + 2]; n + 2];
let mut w = vec![vec![0.0; n + 2]; n + 2];
let mut root = vec![vec![0; n + 1]; n + 1];
// Base cases
for i in 1..=n + 1 {
e[i][i - 1] = q[i - 1];
w[i][i - 1] = q[i - 1];
}
// DP
for l in 1..=n {
for i in 1..=(n - l + 1) {
let j = i + l - 1;
e[i][j] = f64::MAX;
w[i][j] = w[i][j - 1] + p[j] + q[j];
for r in i..=j {
let t = e[i][r - 1] + e[r + 1][j] + w[i][j];
if t < e[i][j] {
e[i][j] = t;
root[i][j] = r;
}
}
}
}
(e, root)
}
fn print_tree(root: &[Vec<usize>], i: usize, j: usize, depth: usize, side: char) {
if i > j {
println!("{:indent$}{} -> d{}", "", side, i - 1, indent = depth * 4);
return;
}
let r = root[i][j];
println!("{:indent$}{} -> k{}", "", side, r, indent = depth * 4);
print_tree(root, i, r - 1, depth + 1, 'L');
print_tree(root, r + 1, j, depth + 1, 'R');
}
fn main() {
let p = vec![0.0, 0.04, 0.06, 0.08, 0.02, 0.10, 0.12, 0.14];
let q = vec![0.06, 0.06, 0.06, 0.06, 0.05, 0.05, 0.05, 0.05];
let (e, root) = optimal_bst(&p, &q);
println!("Optimal Expected Cost: {:.4}\n", e[1][p.len() - 1]);
println!("Tree Structure:");
print_tree(&root, 1, p.len() - 1, 0, 'R');
}Sample Output
Write in lab recordOptimal Expected Cost: 3.1200
Tree Structure:
L -> k5 (p=0.10)
L -> k2 (p=0.06)
L -> k1 (p=0.04)
L -> d0 (q=0.06)
R -> d1 (q=0.06)
R -> k3 (p=0.08)
L -> d2 (q=0.06)
R -> k4 (p=0.02)
L -> d3 (q=0.06)
R -> d4 (q=0.05)
R -> k7 (p=0.14)
L -> k6 (p=0.12)
L -> d5 (q=0.05)
R -> d6 (q=0.05)
R -> d7 (q=0.05)Question 2
Problem Statement
Write in lab recordDetermine the cost and structure of an optimal binary search tree for a set of n = 5 keys with the given properties. Show the step-by-step process.
| i | 0 | 1 | 2 | 3 | 4 | 5 |
|---|---|---|---|---|---|---|
| 0.15 | 0.10 | 0.05 | 0.10 | 0.20 | ||
| 0.05 | 0.10 | 0.05 | 0.05 | 0.05 | 0.10 |
Answer
Write in lab recordDynamic Programming Formulation
We use three tables:
e[i][j]: Expected search cost for keysw[i][j]: Probability weight of subtreeroot[i][j]: Index of the optimal root for subtree
Recurrence Relations:
- Base Case: ,
- Weight Update:
- Cost Update:
Step-by-Step DP Calculation
Write in lab recordStep 1: Base Cases (l = 0)
i | e[i][i-1] | w[i][i-1] |
|---|---|---|
| 1 | 0.05 | 0.05 |
| 2 | 0.10 | 0.10 |
| 3 | 0.05 | 0.05 |
| 4 | 0.05 | 0.05 |
| 5 | 0.05 | 0.05 |
| 6 | 0.10 | 0.10 |
Step 2: Chain Length l = 1
i | j | w[i][j] | e[i][j] | root[i][j] | Calculation (min expression) |
|---|---|---|---|---|---|
| 1 | 1 | 0.30 | 0.45 | 1 | 0.05 + 0.10 + 0.30 |
| 2 | 2 | 0.25 | 0.40 | 2 | 0.10 + 0.05 + 0.25 |
| 3 | 3 | 0.15 | 0.25 | 3 | 0.05 + 0.05 + 0.15 |
| 4 | 4 | 0.20 | 0.30 | 4 | 0.05 + 0.05 + 0.20 |
| 5 | 5 | 0.35 | 0.50 | 5 | 0.05 + 0.10 + 0.35 |
Step 3: Chain Length l = 2
i | j | w[i][j] | e[i][j] | root[i][j] | Best r & Calculation |
|---|---|---|---|---|---|
| 1 | 2 | 0.45 | 0.90 | 1 | r=1: 0.05 + 0.40 + 0.45 |
| 2 | 3 | 0.35 | 0.70 | 2 | r=2: 0.10 + 0.25 + 0.35 |
| 3 | 4 | 0.30 | 0.60 | 4 | r=4: 0.25 + 0.05 + 0.30 |
| 4 | 5 | 0.50 | 0.90 | 5 | r=5: 0.30 + 0.10 + 0.50 |
Step 4: Chain Length l = 3
i | j | w[i][j] | e[i][j] | root[i][j] | Best r & Calculation |
|---|---|---|---|---|---|
| 1 | 3 | 0.55 | 1.25 | 2 | r=2: 0.45 + 0.25 + 0.55 |
| 2 | 4 | 0.50 | 1.20 | 2 | r=2: 0.10 + 0.60 + 0.50 |
| 3 | 5 | 0.60 | 1.30 | 5 | r=5: 0.60 + 0.10 + 0.60 |
Step 5: Chain Length l = 4
i | j | w[i][j] | e[i][j] | root[i][j] | Best r & Calculation |
|---|---|---|---|---|---|
| 1 | 4 | 0.70 | 1.75 | 2 | r=2: 0.45 + 0.60 + 0.70 |
| 2 | 5 | 0.80 | 2.00 | 4 | r=4: 0.70 + 0.50 + 0.80 |
Step 6: Chain Length l = 5 (Full Tree)
i | j | w[i][j] | e[i][j] | root[i][j] | Best r & Calculation |
|---|---|---|---|---|---|
| 1 | 5 | 1.00 | 2.75 | 2 | r=2: 0.45 + 1.30 + 1.00 |
Final DP Tables
Write in lab recordExpected Cost Table e[i][j]
i\j | 1 | 2 | 3 | 4 | 5 |
|---|---|---|---|---|---|
| 1 | 0.45 | 0.90 | 1.25 | 1.75 | 2.75 |
| 2 | — | 0.40 | 0.70 | 1.20 | 2.00 |
| 3 | — | — | 0.25 | 0.60 | 1.30 |
| 4 | — | — | — | 0.30 | 0.90 |
| 5 | — | — | — | — | 0.50 |
Optimal Root Table root[i][j]
i\j | 1 | 2 | 3 | 4 | 5 |
|---|---|---|---|---|---|
| 1 | 1 | 1 | 2 | 2 | 2 |
| 2 | — | 2 | 2 | 2 | 4 |
| 3 | — | — | 3 | 4 | 5 |
| 4 | — | — | — | 4 | 5 |
| 5 | — | — | — | — | 5 |
Optimal Tree Structure
Write in lab recordImplementation
Write in lab recordLab record: write one language only. Pick yours once and every page opens on it; the other tabs are the same solution for comparison.
def optimal_bst(p, q):
    """Compute optimal BST using dynamic programming."""
    n = len(p) - 1
    e = [[0.0] * (n + 2) for _ in range(n + 2)]
    w = [[0.0] * (n + 2) for _ in range(n + 2)]
    root = [[0] * (n + 1) for _ in range(n + 1)]

    # Base cases: empty subtrees
    for i in range(1, n + 2):
        e[i][i - 1] = q[i - 1]
        w[i][i - 1] = q[i - 1]

    # DP over chain length l
    for l in range(1, n + 1):
        for i in range(1, n - l + 2):
            j = i + l - 1
            e[i][j] = float("inf")
            w[i][j] = w[i][j - 1] + p[j] + q[j]

            for r in range(i, j + 1):
                t = e[i][r - 1] + e[r + 1][j] + w[i][j]
                if t < e[i][j]:
                    e[i][j] = t
                    root[i][j] = r
    return e, root


def print_tree(root, p, q, i, j, depth=0, side="R"):
    """Recursively print tree structure."""
    indent = "    " * depth
    if i > j:
        print(f"{indent}{side} -> d{i - 1} (q={q[i - 1]:.2f})")
        return
    r = root[i][j]
    print(f"{indent}{side} -> k{r} (p={p[r]:.2f})")
    print_tree(root, p, q, i, r - 1, depth + 1, "L")
    print_tree(root, p, q, r + 1, j, depth + 1, "R")


if __name__ == "__main__":
    p = [0, 0.15, 0.10, 0.05, 0.10, 0.20]
    q = [0.05, 0.10, 0.05, 0.05, 0.05, 0.10]
    e, root = optimal_bst(p, q)
    print(f"Optimal Expected Cost: {e[1][len(p) - 1]:.4f}\n")
    print("Tree Structure:")
print_tree(root, p, q, 1, len(p) - 1)#include <stdio.h>
#include <float.h>
#define N 5
void construct_optimal_bst(double p[], double q[], double e[][N+2], int root[][N+1]) {
double w[N+2][N+2];
// Base cases
for (int i = 1; i <= N + 1; i++) {
e[i][i-1] = q[i-1];
w[i][i-1] = q[i-1];
}
// DP
for (int l = 1; l <= N; l++) {
for (int i = 1; i <= N - l + 1; i++) {
int j = i + l - 1;
e[i][j] = DBL_MAX;
w[i][j] = w[i][j-1] + p[j] + q[j];
for (int r = i; r <= j; r++) {
double t = e[i][r-1] + e[r+1][j] + w[i][j];
if (t < e[i][j]) {
e[i][j] = t;
root[i][j] = r;
}
}
}
}
}
void print_tree(int root[][N+1], double p[], double q[], int i, int j, int depth, char side) {
if (i > j) {
printf("%*c%c -> d%d (q=%.2f)\n", depth * 4, ' ', side, i-1, q[i-1]);
return;
}
int r = root[i][j];
printf("%*c%c -> k%d (p=%.2f)\n", depth * 4, ' ', side, r, p[r]);
print_tree(root, p, q, i, r-1, depth+1, 'L');
print_tree(root, p, q, r+1, j, depth+1, 'R');
}
int main() {
double p[] = {0, 0.15, 0.10, 0.05, 0.10, 0.20};
double q[] = {0.05, 0.10, 0.05, 0.05, 0.05, 0.10};
double e[N+2][N+2];
int root[N+1][N+1];
construct_optimal_bst(p, q, e, root);
printf("Optimal Expected Cost: %.4f\n\n", e[1][N]);
printf("Tree Structure:\n");
print_tree(root, p, q, 1, N, 0, 'R');
return 0;
}fn optimal_bst(p: &[f64], q: &[f64]) -> (Vec<Vec<f64>>, Vec<Vec<usize>>) {
let n = p.len() - 1;
let mut e = vec![vec![0.0; n + 2]; n + 2];
let mut w = vec![vec![0.0; n + 2]; n + 2];
let mut root = vec![vec![0; n + 1]; n + 1];
for i in 1..=n + 1 {
e[i][i - 1] = q[i - 1];
w[i][i - 1] = q[i - 1];
}
for l in 1..=n {
for i in 1..=(n - l + 1) {
let j = i + l - 1;
e[i][j] = f64::MAX;
w[i][j] = w[i][j - 1] + p[j] + q[j];
for r in i..=j {
let t = e[i][r - 1] + e[r + 1][j] + w[i][j];
if t < e[i][j] {
e[i][j] = t;
root[i][j] = r;
}
}
}
}
(e, root)
}
fn print_tree(
root: &[Vec<usize>],
p: &[f64],
q: &[f64],
i: usize,
j: usize,
depth: usize,
side: char,
) {
if i > j {
println!(
"{:indent$}{} -> d{} (q={:.2f})",
"",
side,
i - 1,
q[i - 1],
indent = depth * 4
);
return;
}
let r = root[i][j];
println!(
"{:indent$}{} -> k{} (p={:.2f})",
"",
side,
r,
p[r],
indent = depth * 4
);
print_tree(root, p, q, i, r - 1, depth + 1, 'L');
print_tree(root, p, q, r + 1, j, depth + 1, 'R');
}
fn main() {
let p = vec![0.0, 0.15, 0.10, 0.05, 0.10, 0.20];
let q = vec![0.05, 0.10, 0.05, 0.05, 0.05, 0.10];
let (e, root) = optimal_bst(&p, &q);
println!("Optimal Expected Cost: {:.4}\n", e[1][p.len() - 1]);
println!("Tree Structure:");
print_tree(&root, &p, &q, 1, p.len() - 1, 0, 'R');
}Sample Output
Write in lab recordOptimal Expected Cost: 2.7500
Tree Structure:
R -> k2 (p=0.10)
L -> k1 (p=0.15)
L -> d0 (q=0.05)
R -> d1 (q=0.10)
R -> k5 (p=0.20)
L -> k4 (p=0.10)
L -> k3 (p=0.05)
L -> d2 (q=0.05)
R -> d3 (q=0.05)
R -> d4 (q=0.05)
R -> d5 (q=0.10)Question 3
Problem Statement
Write in lab recordImplement the optimal binary search tree algorithm on your system and study the performance of the algorithm on different problem instances
Approach
Do not copy. Read for understanding and the vivaHand-worked DP tables are fine for small n, but studying performance across instances needs:
Automated execution: the same DP logic runs on both problem instances, with no transcription errors.
Quantitative metrics: execution time, a count of primitive operations (inner-loop iterations), and memory footprint.
Empirical validation: showing how the time complexity scales even between small instances (n = 5 and n = 7).
Performance Metrics
Do not copy. Read for understanding and the viva| Metric | Description | Why it matters |
|---|---|---|
| Execution time | Wall-clock time from a high-resolution timer | Real-world runtime behaviour |
| DP operations | Count of inner-loop comparisons (t < e[i][j]) | Algorithmic work, independent of hardware |
| Space | Floating-point cells allocated, 3 × (n+2)² | Memory footprint for large inputs |
| Optimal cost | Final e[1][n] | Correctness check |
Execution Results
Write in lab record| Instance | Optimal Cost | DP Operations (exact) | Python Time | C Time | Rust Time | Memory Cells () | |
|---|---|---|---|---|---|---|---|
| Problem 2 | 5 | 2.7500 | 35 | 4.2 µs | 0.8 µs | 0.7 µs | 147 |
| Problem 1 | 7 | 3.1200 | 84 | 9.1 µs | 1.4 µs | 1.3 µs | 243 |
Times vary from machine to machine; the operation counts and costs do not. The inner loop runs
Analysis and Conclusion
Write in lab recordEven at small , the operation count jumps from 35 to 84 when goes from 5 to 7, a ratio of . The count is , which grows as : the lower-order terms keep the ratio below for small inputs, and it approaches the cube ratio as grows. This confirms the cubic complexity of the algorithm.
Space Complexity
All implementations allocate three tables.
- n = 5: 147 doubles, about 1.15 KB
- n = 7: 243 doubles, about 1.90 KB
- Space is trivial for n up to 500 but grows quadratically. For n above 1000, consider:
- Rolling arrays, which reduce
wandeto O(n) space - Knuth’s root-restriction optimisation, which brings time down to
- Rolling arrays, which reduce
Implementation
Write in lab recordLab record: write one language only. Pick yours once and every page opens on it; the other tabs are the same solution for comparison.
import time
import sys

def optimal_bst(p, q, name="Instance"):
    """
    Dynamic Programming solution for Optimal Binary Search Tree.
    Tracks execution time and inner-loop operation count.
    """
    n = len(p) - 1  # p is 1-indexed
    ops = 0  # Counts primitive comparisons

    # Allocate DP tables: e[cost], w[weight], root[index]
    e = [[0.0] * (n + 2) for _ in range(n + 2)]
    w = [[0.0] * (n + 2) for _ in range(n + 2)]
    root = [[0] * (n + 1) for _ in range(n + 1)]

    # Base case: subtrees containing only dummy keys
    for i in range(1, n + 2):
        e[i][i - 1] = q[i - 1]
        w[i][i - 1] = q[i - 1]

    # High-resolution timing start
    start = time.perf_counter()

    # DP over chain length l = 1 to n
    for l in range(1, n + 1):
        for i in range(1, n - l + 2):
            j = i + l - 1
            e[i][j] = float('inf')
            # Weight recurrence: O(1) per cell
            w[i][j] = w[i][j - 1] + p[j] + q[j]

            # Try every key r in [i, j] as root: O(n) per cell
            for r in range(i, j + 1):
                t = e[i][r - 1] + e[r + 1][j] + w[i][j]
                ops += 1  # Track primitive operation
                if t < e[i][j]:
                    e[i][j] = t
                    root[i][j] = r

    # Timing end
    elapsed = (time.perf_counter() - start) * 1_000_000  # Convert to microseconds

    print(f"[{name}] Optimal Cost: {e[1][n]:.4f} | Time: {elapsed:.2f} µs | Ops: {ops}")
    return e[1][n], ops, elapsed

if __name__ == "__main__":
    print("🔬 OBST Performance Study (Python)\n")
    # Instance 1 (n=7)
    p1 = [0, 0.04, 0.06, 0.08, 0.02, 0.10, 0.12, 0.14]
    q1 = [0.06, 0.06, 0.06, 0.06, 0.05, 0.05, 0.05, 0.05]
    optimal_bst(p1, q1, "Problem 1 (n=7)")

    # Instance 2 (n=5)
    p2 = [0, 0.15, 0.10, 0.05, 0.10, 0.20]
    q2 = [0.05, 0.10, 0.05, 0.05, 0.05, 0.10]
optimal_bst(p2, q2, "Problem 2 (n=5)")#include <stdio.h>
#include <stdlib.h>
#include <time.h>
#include <float.h>
#define MAX_N 50 // Safe upper bound for small instances
typedef struct {
double cost;
long ops;
double time_us;
} Result;
Result optimal_bst(double p[], double q[], int n, const char* name) {
// Allocate 2D tables on heap to avoid stack overflow for larger n
double (*e)[MAX_N+2] = calloc(n + 2, sizeof(double[MAX_N+2]));
double (*w)[MAX_N+2] = calloc(n + 2, sizeof(double[MAX_N+2]));
int (*root)[MAX_N+1] = calloc(n + 1, sizeof(int[MAX_N+1]));
long ops = 0;
// Base case initialization
for (int i = 1; i <= n + 1; i++) {
e[i][i-1] = q[i-1];
w[i][i-1] = q[i-1];
}
struct timespec start, end;
clock_gettime(CLOCK_MONOTONIC, &start);
// DP recurrence: O(n^3) time, O(n^2) space
for (int l = 1; l <= n; l++) {
for (int i = 1; i <= n - l + 1; i++) {
int j = i + l - 1;
e[i][j] = DBL_MAX;
w[i][j] = w[i][j-1] + p[j] + q[j];
for (int r = i; r <= j; r++) {
double t = e[i][r-1] + e[r+1][j] + w[i][j];
ops++; // Count comparison operation
if (t < e[i][j]) {
e[i][j] = t;
root[i][j] = r;
}
}
}
}
clock_gettime(CLOCK_MONOTONIC, &end);
double elapsed_us = (end.tv_sec - start.tv_sec) * 1e6 + (end.tv_nsec - start.tv_nsec) / 1e3;
printf("[%s] Optimal Cost: %.4f | Time: %.2f µs | Ops: %ld\n",
name, e[1][n], elapsed_us, ops);
Result res = {e[1][n], ops, elapsed_us};
free(e); free(w); free(root);
return res;
}
int main() {
printf("🔬 OBST Performance Study (C)\n\n");
// Problem 1 (n=7)
double p1[] = {0, 0.04, 0.06, 0.08, 0.02, 0.10, 0.12, 0.14};
double q1[] = {0.06, 0.06, 0.06, 0.06, 0.05, 0.05, 0.05, 0.05};
optimal_bst(p1, q1, 7, "Problem 1 (n=7)");
// Problem 2 (n=5)
double p2[] = {0, 0.15, 0.10, 0.05, 0.10, 0.20};
double q2[] = {0.05, 0.10, 0.05, 0.05, 0.05, 0.10};
optimal_bst(p2, q2, 5, "Problem 2 (n=5)");
return 0;
}use std::time::Instant;
/// Structure to hold performance metrics for a single run
struct BenchResult {
optimal_cost: f64,
operations: usize,
time_us: f64,
}
fn optimal_bst(p: &[f64], q: &[f64], name: &str) -> BenchResult {
let n = p.len() - 1;
let mut ops = 0;
// Allocate DP tables with 1-based indexing padding
let mut e = vec![vec![0.0; n + 2]; n + 2];
let mut w = vec![vec![0.0; n + 2]; n + 2];
let mut root = vec![vec![0usize; n + 1]; n + 1];
// Base case: empty subtrees
for i in 1..=n + 1 {
e[i][i - 1] = q[i - 1];
w[i][i - 1] = q[i - 1];
}
let start = Instant::now();
// DP over chain length l
for l in 1..=n {
for i in 1..=(n - l + 1) {
let j = i + l - 1;
e[i][j] = f64::MAX;
w[i][j] = w[i][j - 1] + p[j] + q[j];
// Root selection loop
for r in i..=j {
let t = e[i][r - 1] + e[r + 1][j] + w[i][j];
ops += 1;
if t < e[i][j] {
e[i][j] = t;
root[i][j] = r;
}
}
}
}
let elapsed_us = start.elapsed().as_secs_f64() * 1_000_000.0;
println!(
"[{}] Optimal Cost: {:.4} | Time: {:.2} µs | Ops: {}",
name, e[1][n], elapsed_us, ops
);
BenchResult {
optimal_cost: e[1][n],
operations: ops,
time_us: elapsed_us,
}
}
fn main() {
println!("🔬 OBST Performance Study (Rust)\n");
// Problem 1 (n=7)
let p1 = vec![0.0, 0.04, 0.06, 0.08, 0.02, 0.10, 0.12, 0.14];
let q1 = vec![0.06, 0.06, 0.06, 0.06, 0.05, 0.05, 0.05, 0.05];
optimal_bst(&p1, &q1, "Problem 1 (n=7)");
// Problem 2 (n=5)
let p2 = vec![0.0, 0.15, 0.10, 0.05, 0.10, 0.20];
let q2 = vec![0.05, 0.10, 0.05, 0.05, 0.05, 0.10];
optimal_bst(&p2, &q2, "Problem 2 (n=5)");
}Sample Output
Write in lab record🔬 OBST Performance Study (Python)
[Problem 1 (n=7)] Optimal Cost: 3.1200 | Time: 13.54 µs | Ops: 84
[Problem 2 (n=5)] Optimal Cost: 2.7500 | Time: 5.08 µs | Ops: 35